How is a Humanoid Robot Technically Constructed?
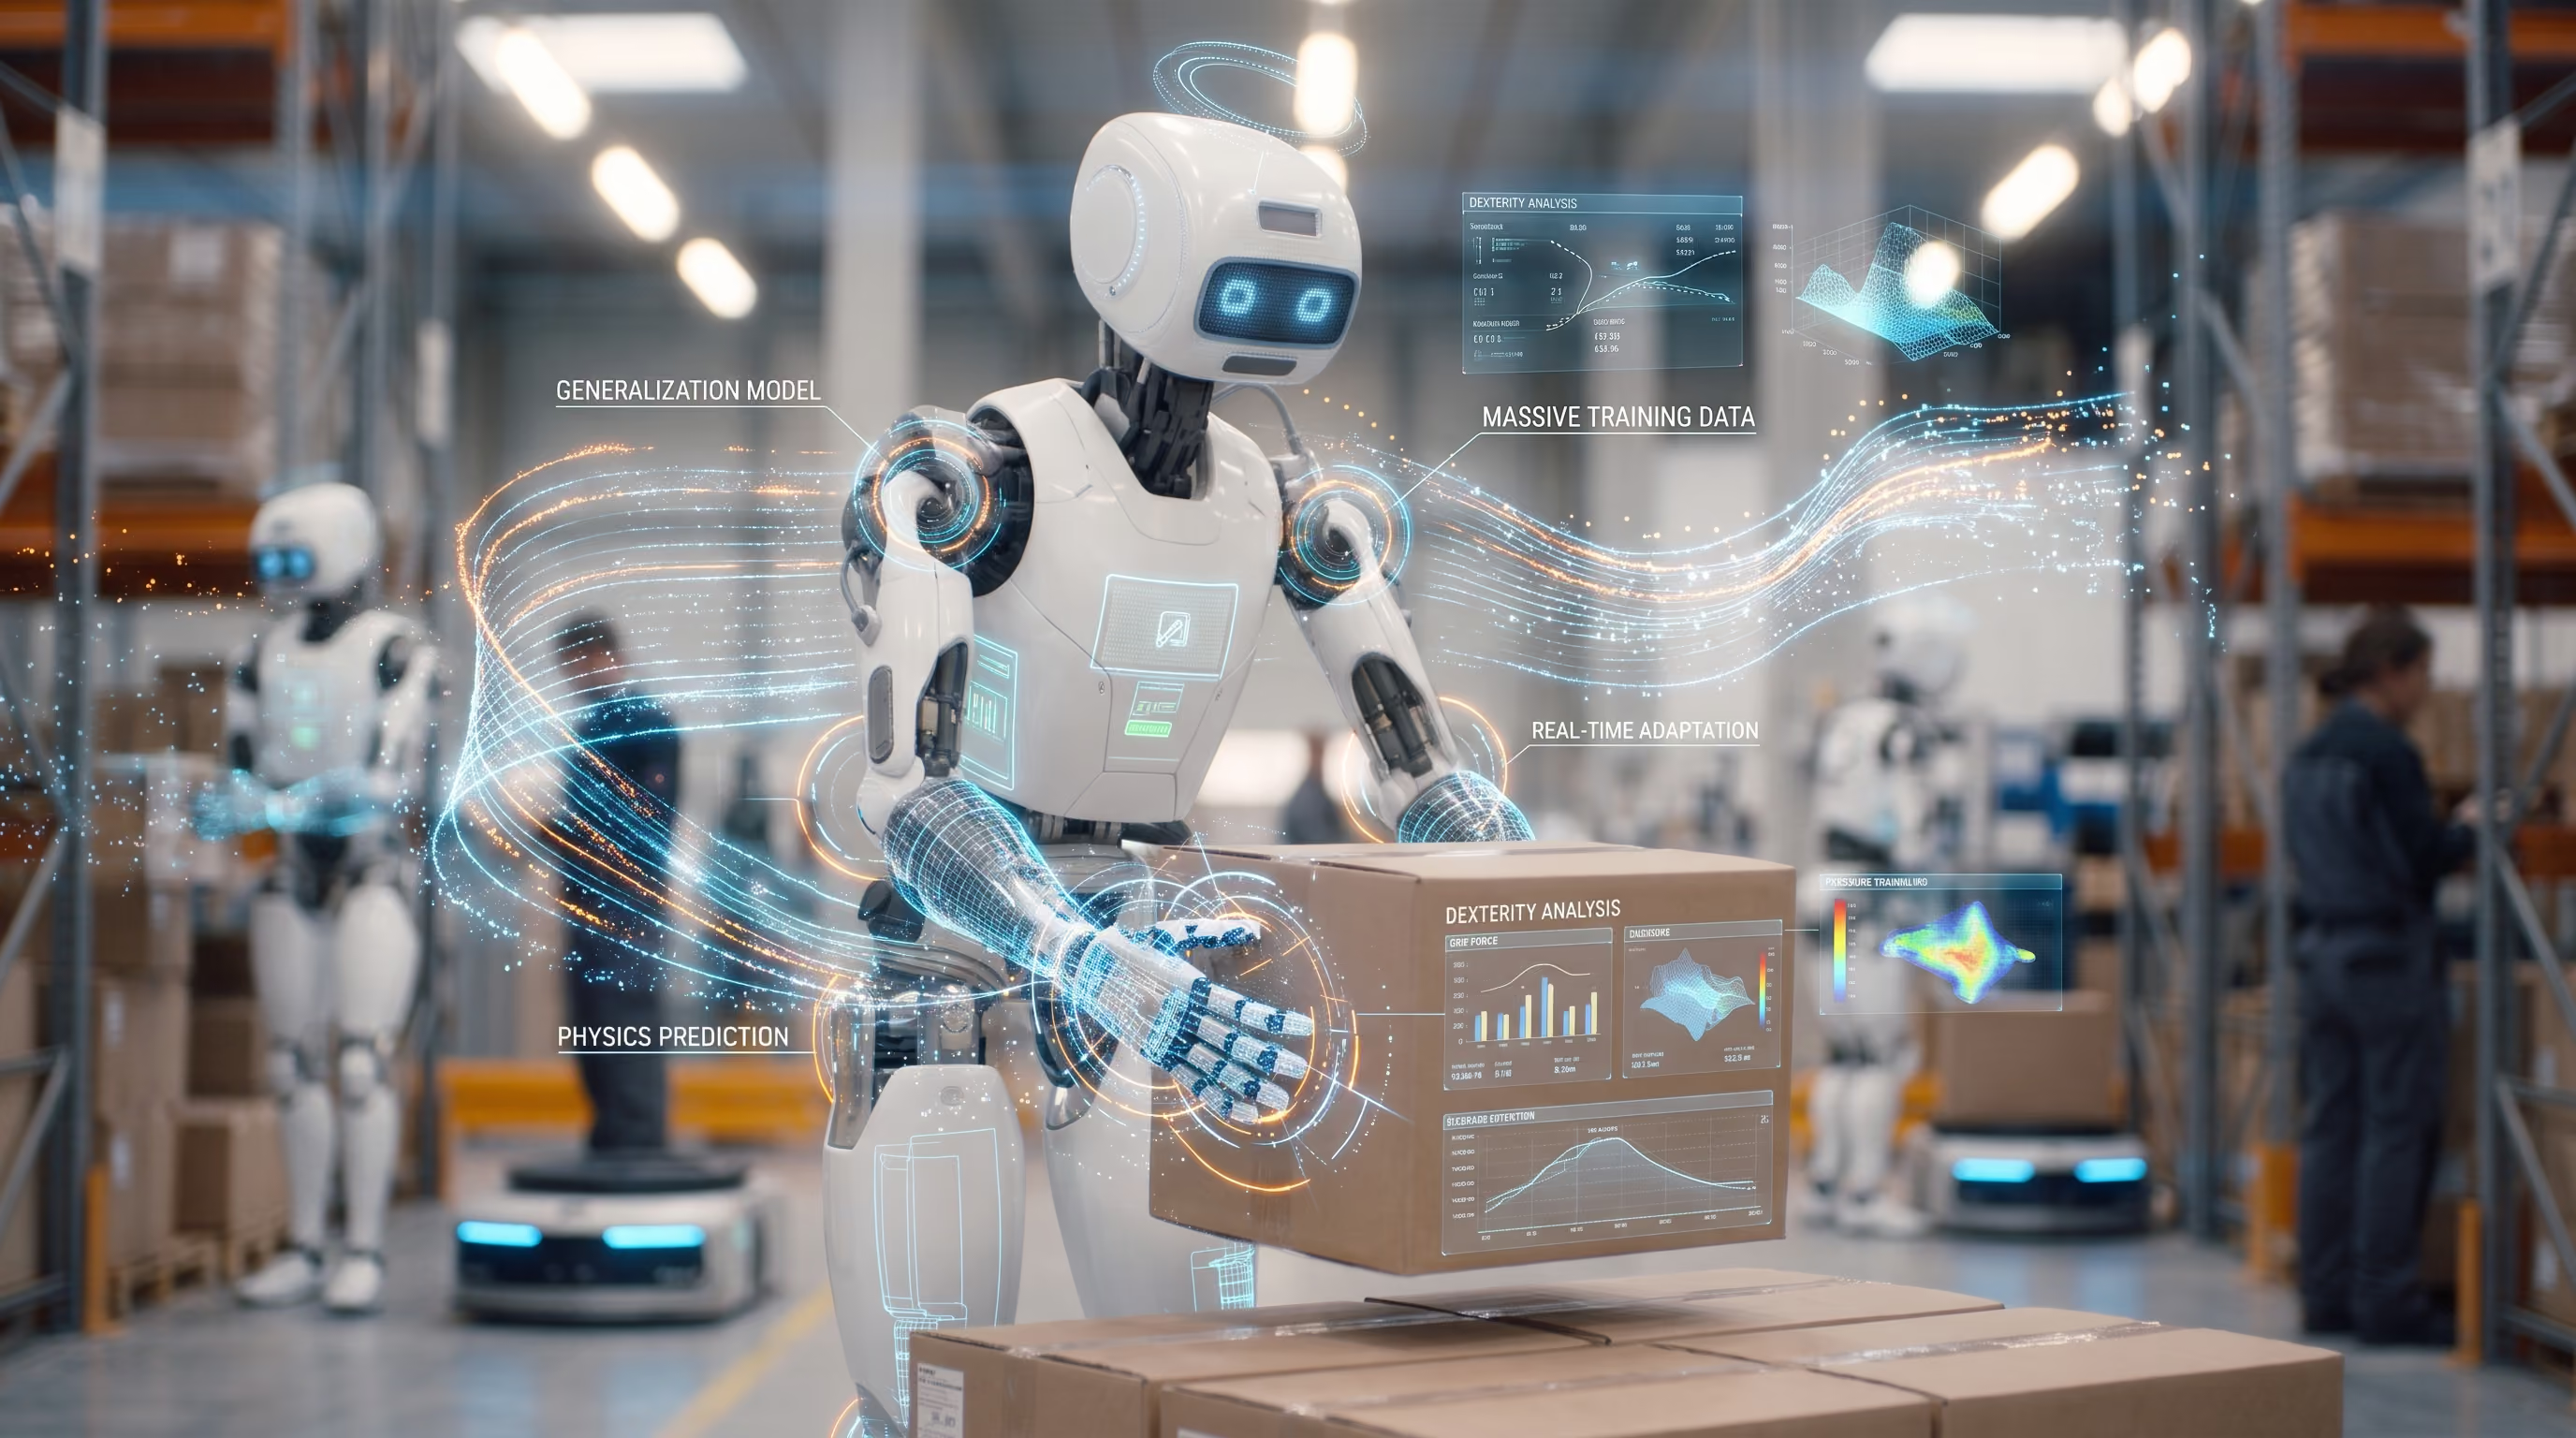
At its core, a humanoid robot is a physical AI system in human form, where the body, senses, and a learning "brain" must work together in real time. Its body typically has several dozen joints, known as degrees of freedom. Each of these requires an actuator consisting of a motor, gearbox, and sensors, which must be compact and powerful, yet compliant enough for safe interaction with people and objects. One of the greatest technical challenges is the hand. To use tools or grasp various parts, it requires many degrees of freedom as well as force and tactile sensors in a very confined space. Bipedal walking requires constant balance control, which is now frequently trained in simulations using reinforcement learning and then transferred to the actual robot. The robot perceives its environment via cameras, depth sensors, and sometimes LiDAR, while determining its own position using inertial sensors and joint encoders. Robotics foundation models, such as vision-language-action models, serve as the "brain"; these run on an edge computer inside the robot and generate movements based on images and instructions. Battery life limits operating time, which is why fast-charging or autonomously swappable batteries are being developed for multi-shift operations.
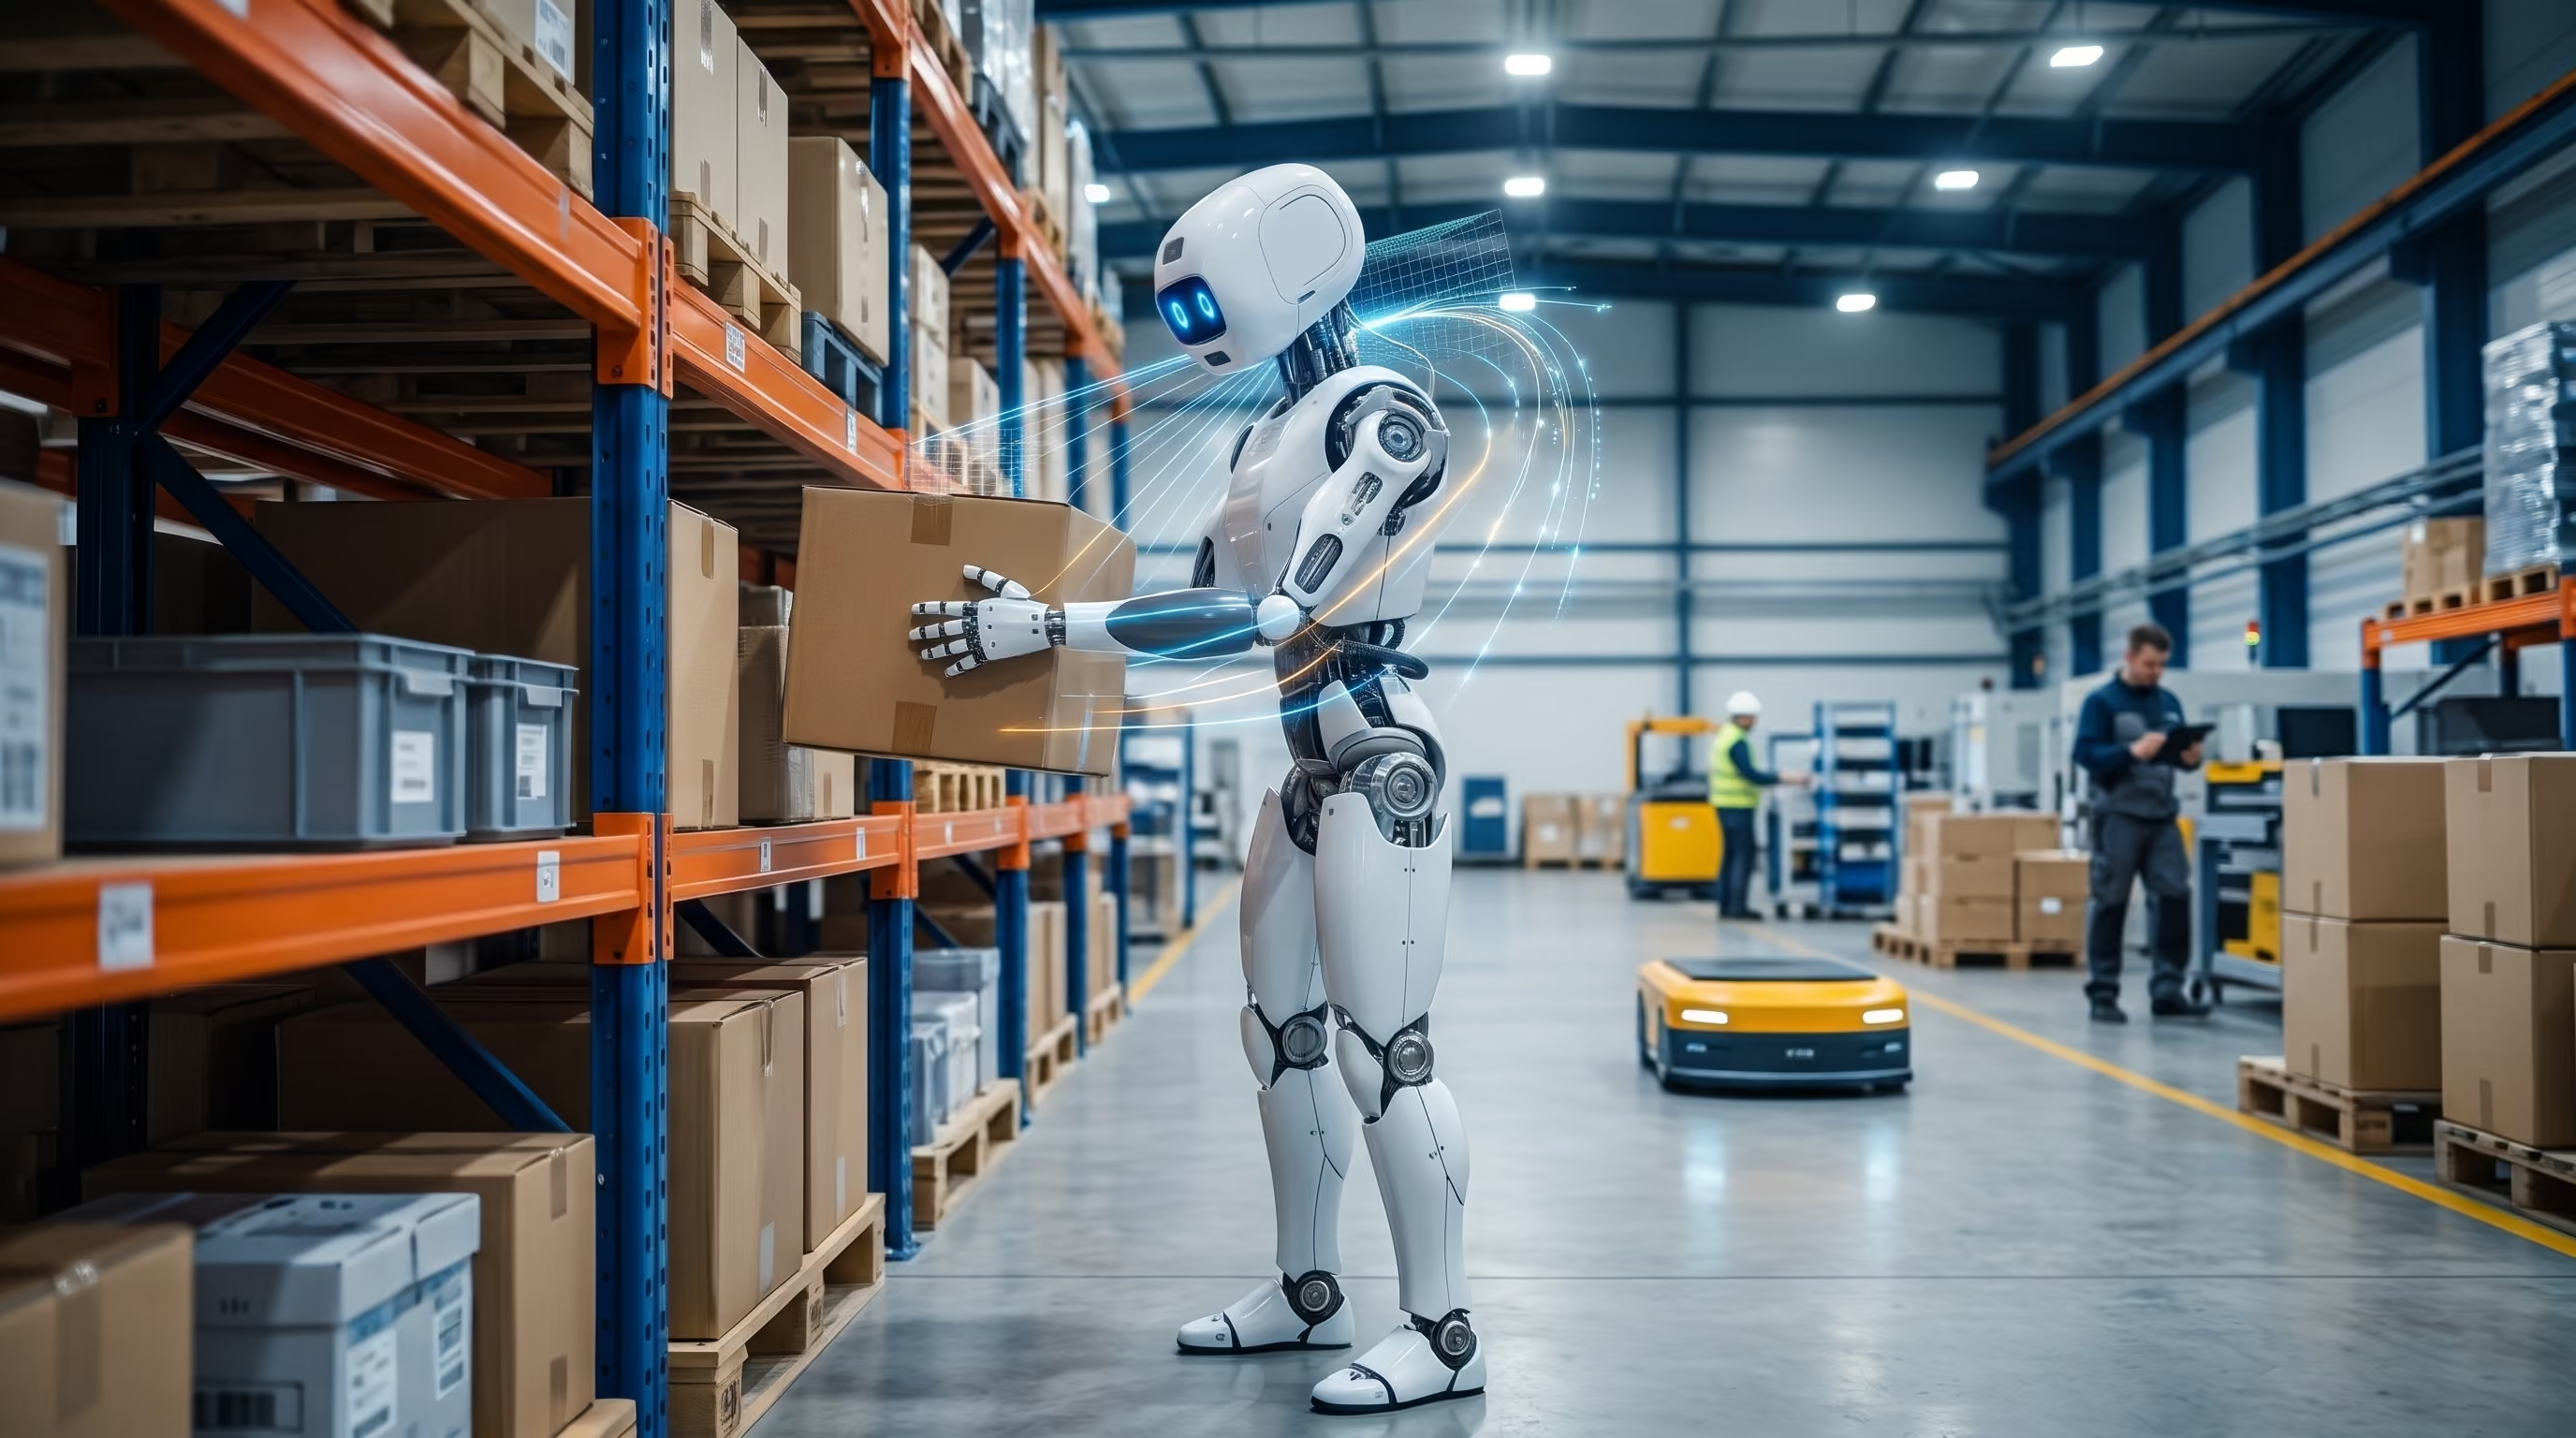
The most well-known pilot projects are underway in the automotive industry and contract logistics, for example at BMW, Mercedes-Benz, and GXO. At the BMW plant in Leipzig, the batteries last about three to four hours depending on the task and are changed by the robot itself. The robots take over repetitive tasks in structured environments: moving containers, inserting parts, and providing materials. Independent data on cycle times, failure rates, and economic viability are currently scarce; many figures come directly from the manufacturers.